SCOPE-4D: Endoscopic 4D Geometry Foundation Models
Structured Camera and Organ Motion Prediction for Endoscopy
Camera, dense geometry and 3D tissue trajectories from monocular video, in one forward pass
1SCOPE-5K · Data 4,910 clips · gastrointestinal endoscopy and laparoscopy
2SCOPE-4D · Model one model, one forward pass
Depth and geometry
Laparoscopy (top) and colonoscopy (bottom).
3D tissue trajectories
Long sequences
Abstract
Geometric understanding supports endoscopic navigation and robotic assistance, but learning reliable endoscopic geometry faces two challenges: scarce geometric annotations and ambiguity between camera motion and tissue deformation. We present SCOPE-4D, an endoscopic 4D geometry foundation model that jointly predicts camera parameters, dense geometry, and 3D tissue trajectories from monocular RGB video in a single forward pass. Our curation and annotation pipeline constructs SCOPE-5K, a collection of approximately 5,000 clips spanning real and synthetic gastrointestinal endoscopy and laparoscopy. The collection provides rich geometric supervision and includes newly collected phantom and real-colonoscopy evaluation sets. Geometric supervised fine-tuning on SCOPE-5K learns endoscopic priors that improve camera and depth estimation. Common–Residual Motion (CRM) further constrains local deformation relative to common tissue movement. Together with geometric supervision, CRM and trajectory supervision further improve camera and depth estimation over geometric fine-tuning alone while enabling dense 3D tissue tracking. Evaluations on public and newly collected benchmarks demonstrate strong in-domain and out-of-domain geometry, superior 3D tracking, and more stable long-sequence colon reconstruction. A blinded user study further supports the perceived reconstruction quality on real clinical video. Together, these results demonstrate the value of large-scale endoscopic supervision and motion constraints for joint geometry estimation and tissue tracking.
Overview
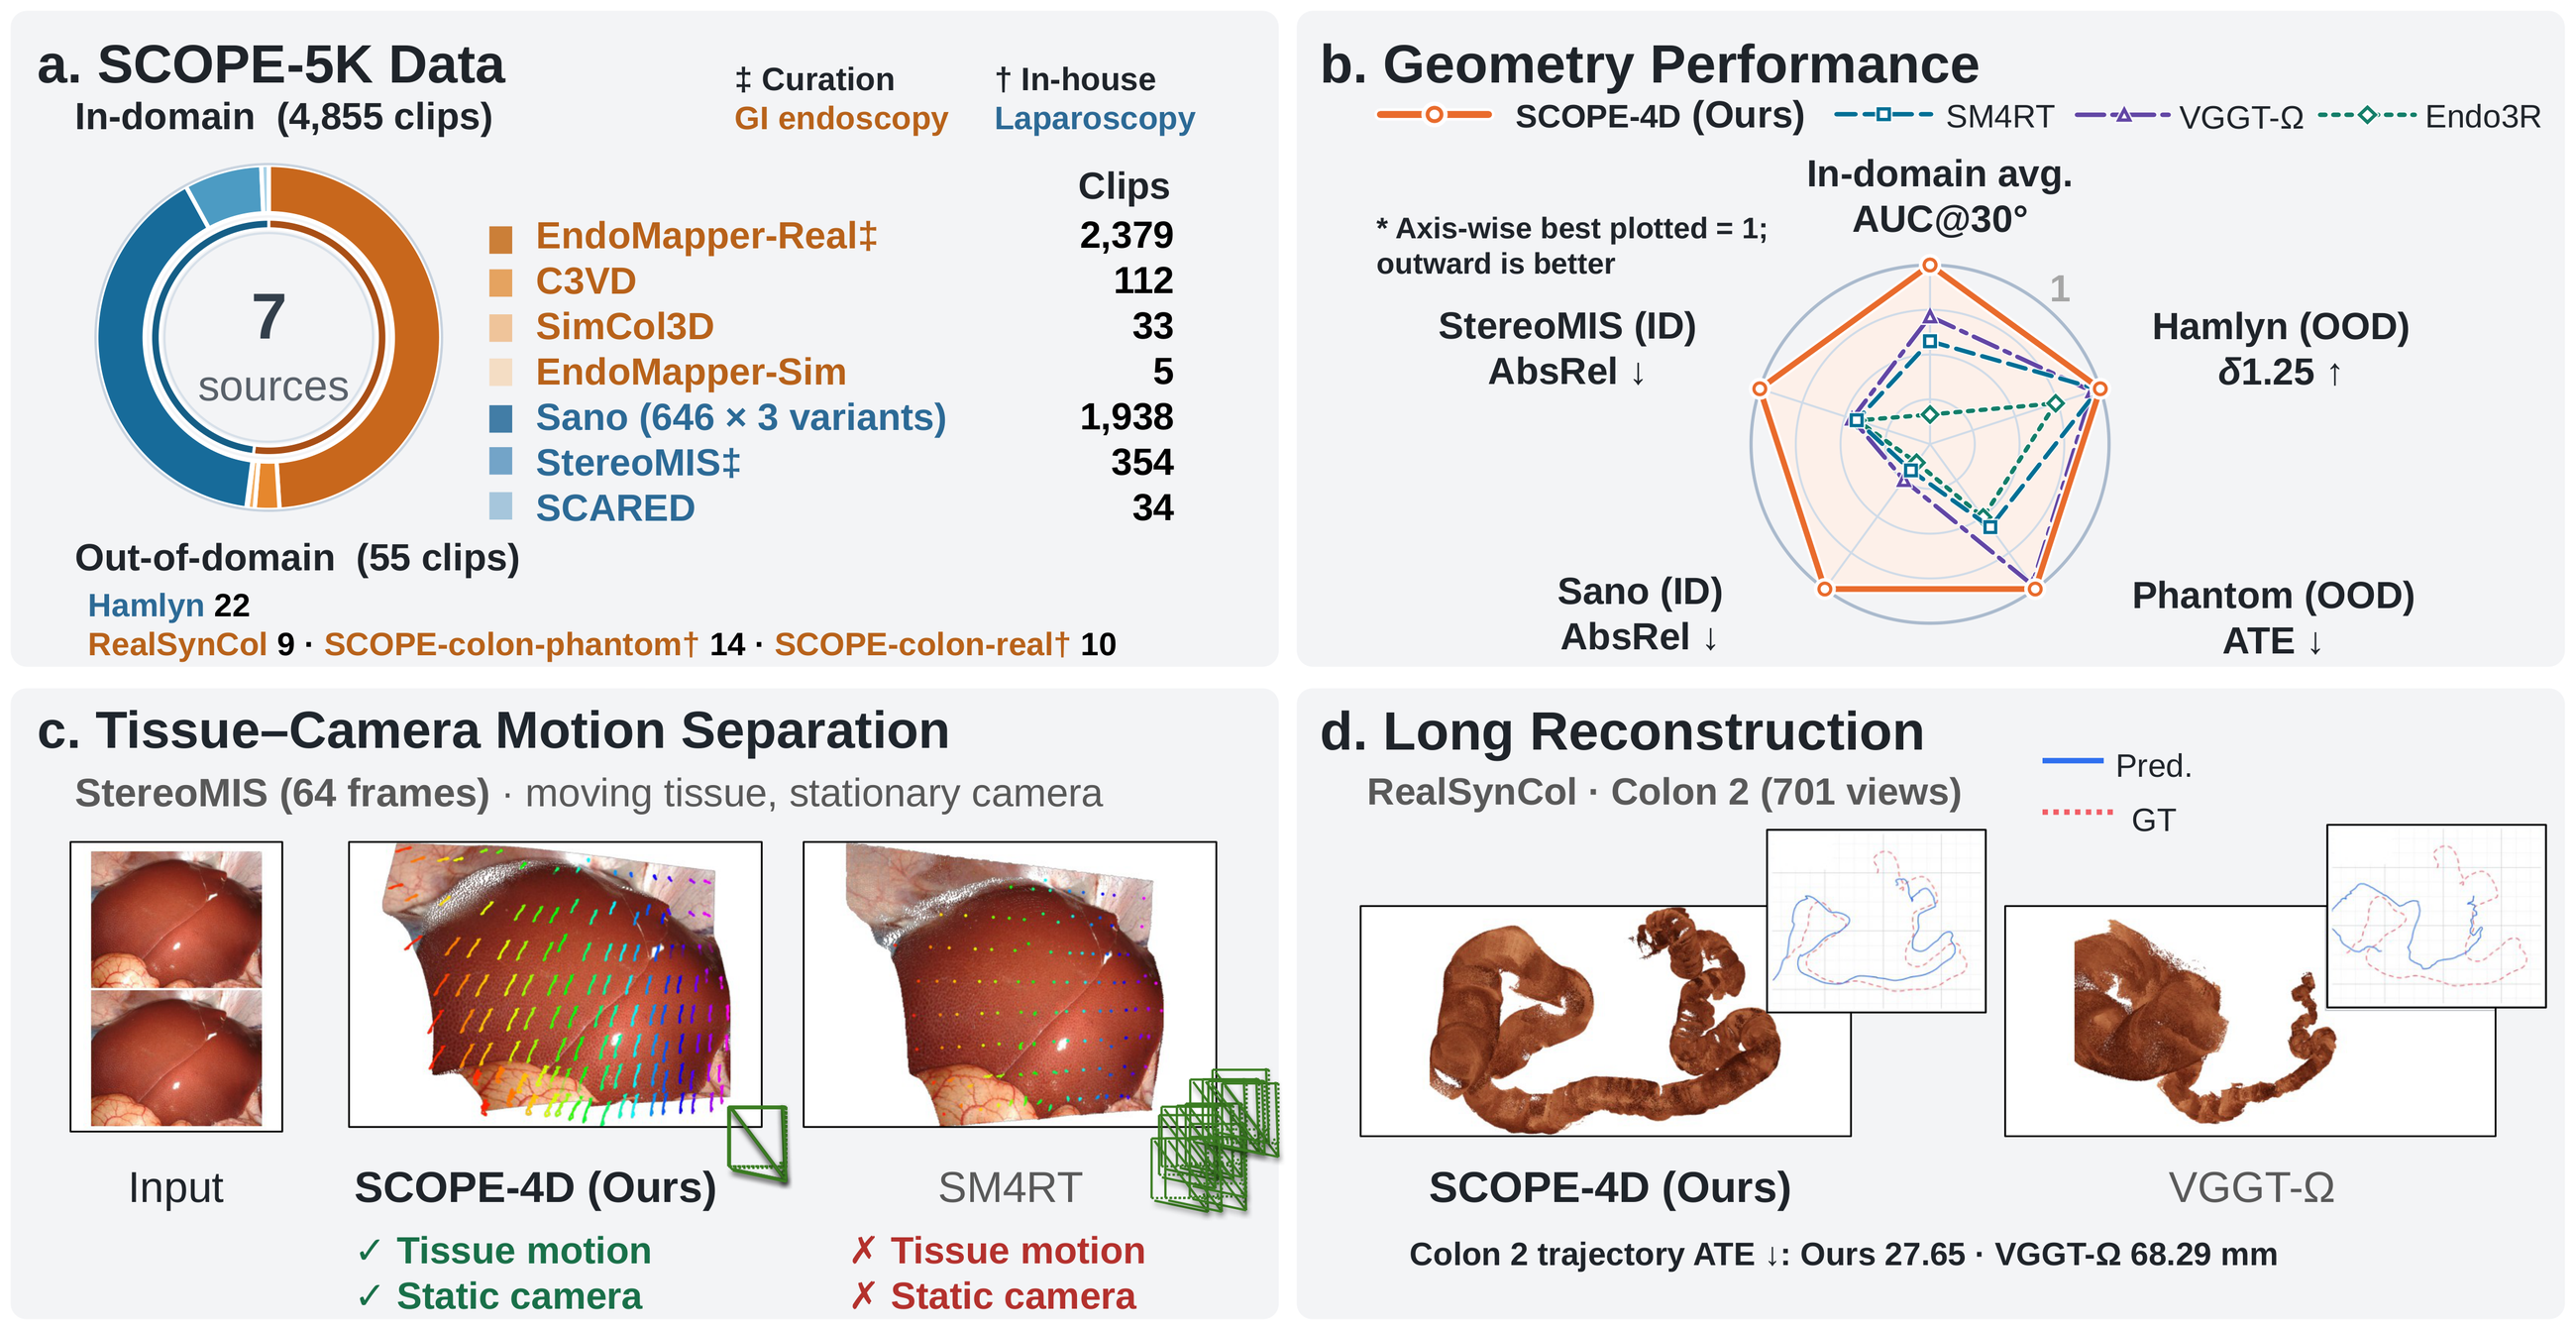
Method
SCOPE-4D builds on a feed-forward multi-view transformer. Geometric fine-tuning on SCOPE-5K supervises camera and dense depth. CRM represents each 3D point's motion as a shared common motion plus a local residual. Together with geometric supervision, CRM and trajectory supervision further improve camera and depth estimation over geometric fine-tuning alone while enabling dense 3D tissue tracking.
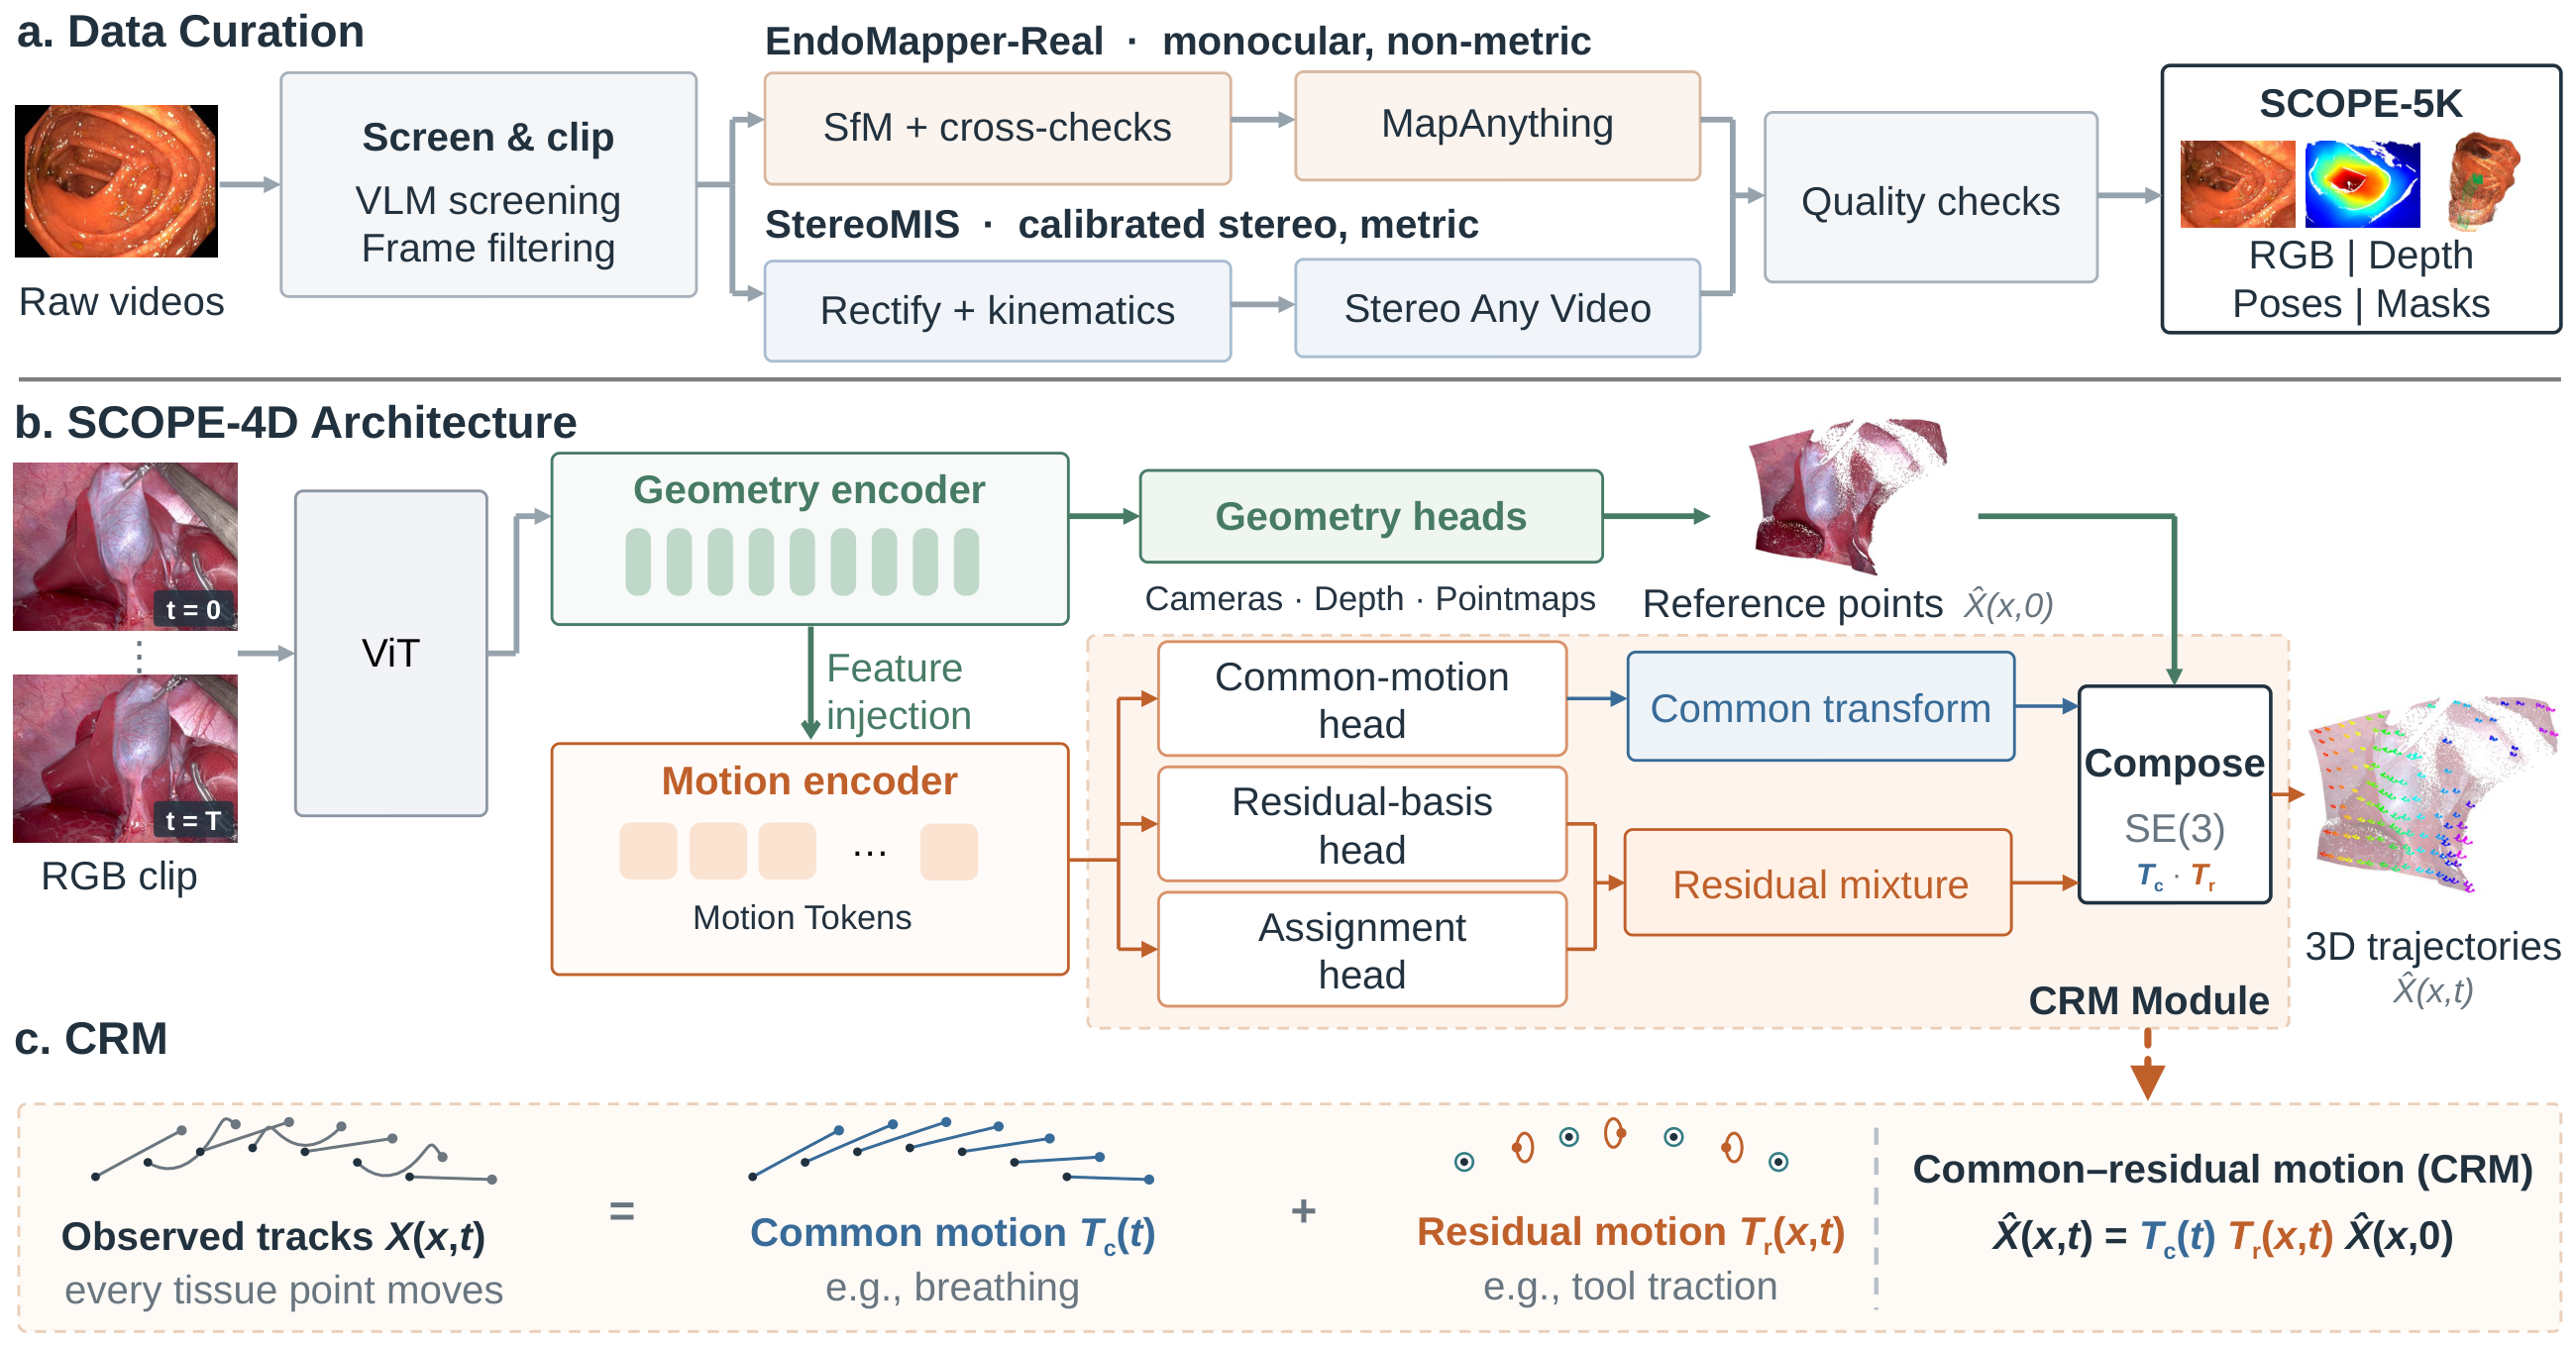
SCOPE-5K data
Real endoscopic video rarely comes with geometry. Our pipeline (panel a of the method figure) turns raw videos into clips with camera and depth labels: screening and clipping, per-clip structure-from-motion with tracking-based correspondences, dense labels from a camera-conditioned geometry model, and an automatic quality-control stage that accepts, flags or rejects each clip.
Data composition
| Data source | GI | Laparo | Synthetic | Real | Depth | Camera | Clips |
|---|---|---|---|---|---|---|---|
| EndoMapper-Real | ✓ | ✓ | ✓† | ✓† | 2,379 | ||
| C3VD | ✓ | ✓ | ✓ | ✓ | 112 | ||
| SimCol3D | ✓ | ✓ | ✓ | ✓ | 33 | ||
| EndoMapper-Sim | ✓ | ✓ | ✓ | ✓ | 5 | ||
| Sano | ✓ | ✓ | ✓ | ✓ | 1,938 | ||
| StereoMIS | ✓ | ✓ | ✓† | ✓ | 354 | ||
| SCARED | ✓ | ✓ | ✓ | ✓ | 34 | ||
| Hamlyn | ✓ | ✓ | ✓ | 22 | |||
| RealSynCol | ✓ | ✓ | ✓ | ✓ | 9 | ||
| SCOPE-colon-phantom (new) | ✓ | ✓ | ✓ | 14 | |||
| SCOPE-colon-real (new) | ✓ | ✓ | 10 | ||||
| SCOPE-5K | ✓ | ✓ | ✓ | ✓ | ✓ | ✓ | 4,910 |
† annotations generated by our pipeline.
Quality-control examples: one clip per verdict
Accept
Borderline
Reject
Results
Geometry and camera stability Hamlyn, out-of-domain
More examples: EndoMapper-Real; StereoMIS; SCOPE-colon-phantom
EndoMapper-Real
EndoMapper-Real
StereoMIS
SCOPE-colon-phantom
3D tissue tracking StereoMIS
Liver breathing
Instrument pulling tissue
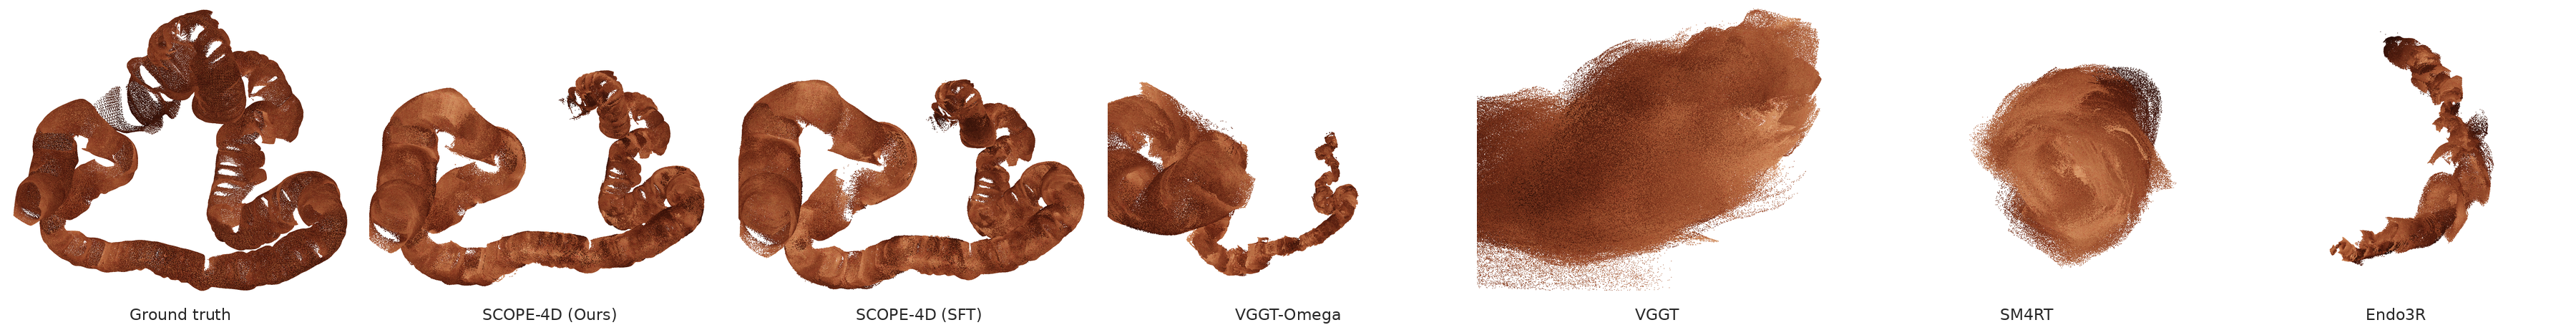
Long-sequence colon reconstruction RealSynCol, 701 views
Interactive demo
Comparison
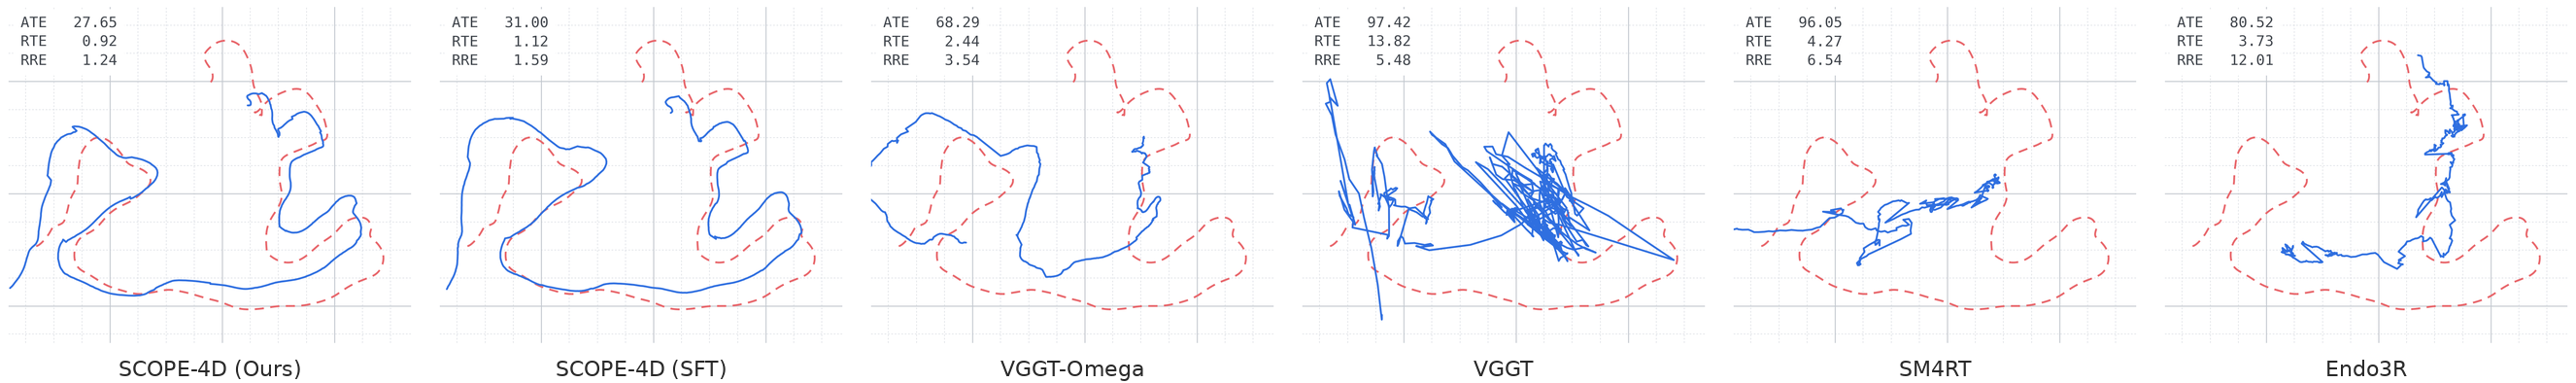
Predicted trajectory GT trajectory
Quantitative results
| Method | In-domain average | Hamlyn (OOD) | SCOPE-colon-phantom (OOD) | |||||||||
|---|---|---|---|---|---|---|---|---|---|---|---|---|
| Pose | Depth | Pose | Depth | Pose | ||||||||
| AUC@5°↑ | AUC@30°↑ | ATE↓ | AbsRel↓ | δ1.25↑ | ATE↓ | ARE↓ | AbsRel↓ | δ1.25↑ | ATE↓ | RTE↓ | ARE*↓ | |
| General-domain | ||||||||||||
| VGGT | 2.94 | 29.11 | 0.128 | 0.160 | 74.61 | 4.610 | 1.964 | 0.190 | 69.19 | 16.53 | 16.78 | 12.14 |
| VGGT-Ω | 7.81 | 48.07 | 0.049 | 0.093 | 91.07 | 4.496 | 1.746 | 0.135 | 80.82 | 8.54 | 10.79 | 8.22 |
| MapAnything | 2.63 | 26.22 | 0.122 | 0.141 | 85.00 | 4.984 | 1.960 | 0.166 | 74.15 | 15.98 | 17.70 | 26.98 |
| CUT3R | 0.27 | 15.55 | 0.131 | 0.300 | 54.06 | 4.571 | 1.693 | 0.185 | 70.27 | 13.64 | 16.56 | 22.48 |
| SpatialTrackerV2 | 6.01 | 44.85 | 0.058 | 0.113 | 86.98 | 5.499 | 2.241 | 0.142 | 77.42 | 10.92 | 13.80 | 11.23 |
| 4RC | 6.12 | 41.85 | 0.068 | 0.138 | 79.71 | 3.639 | 1.438 | 0.120 | 84.26 | 13.98 | 15.33 | 9.13 |
| Any4D | 0.29 | 11.18 | 0.160 | 0.215 | 65.25 | 4.755 | 1.114 | 0.167 | 72.23 | 16.94 | 17.57 | 12.15 |
| SM4RT | 4.86 | 38.72 | 0.087 | 0.147 | 77.78 | 3.517 | 1.350 | 0.120 | 83.94 | 14.46 | 15.50 | 9.17 |
| Endoscopy-specific | ||||||||||||
| Endo3R | 0.26 | 11.14 | 0.179 | 0.185 | 70.06 | 20.982 | 9.492 | 0.223 | 62.77 | 16.42 | 17.05 | 16.13 |
| AF-SfMLearner | 1.45 | 20.76 | 0.134 | 0.253 | 56.94 | 15.562 | 5.979 | 0.190 | 68.20 | 10.35 | 13.88 | 10.31 |
| EndoDAC | 1.41 | 19.08 | 0.130 | 0.201 | 66.22 | 18.057 | 8.968 | 0.191 | 68.87 | 11.51 | 15.03 | 10.54 |
| Endo-FASt3R | 4.13 | 35.02 | 0.062 | 0.230 | 60.39 | 9.152 | 3.794 | 0.211 | 64.75 | 8.70 | 11.39 | 9.22 |
| SCOPE-4DSFT (Ours) | 29.44 | 67.33 | 0.016 | 0.042 | 98.52 | 2.927 | 1.014 | 0.129 | 83.77 | 8.41 | 10.71 | 7.37 |
| SCOPE-4D (Ours) | 29.86 | 67.41 | 0.017 | 0.040 | 98.68 | 2.976 | 1.013 | 0.124 | 85.23 | 8.29 | 10.82 | 7.21 |
Camera and depth. Hamlyn depth excludes instruments. Bold best, underline second.
| Method | Sano | StereoMIS | ||||||||||||
|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|
| Tracking | Pose | Depth | Tracking | Pose | Depth | |||||||||
| EPE↓ | APD↑ | ATE↓ | RTE↓ | RRE↓ | AbsRel↓ | δ1.25↑ | EPE↓ | APD↑ | ATE↓ | RTE↓ | RRE↓ | AbsRel↓ | δ1.25↑ | |
| D4RT* | 2.035 | 72.94 | 0.014 | 0.239 | 0.215 | 0.193 | 65.76 | 7.540 | 34.12 | 0.043 | 0.940 | 0.344 | 0.147 | 87.20 |
| SpatialTrackerV2 | 0.933 | 90.58 | 0.017 | 0.223 | 0.125 | 0.145 | 78.76 | 6.870 | 38.98 | 0.049 | 0.677 | 0.195 | 0.107 | 95.24 |
| 4RC | 0.523 | 94.72 | 0.006 | 0.100 | 0.062 | 0.186 | 66.15 | 6.266 | 44.28 | 0.039 | 0.481 | 0.146 | 0.114 | 90.42 |
| Any4D | 0.535 | 94.41 | 0.010 | 0.376 | 0.309 | 0.188 | 66.01 | 7.277 | 42.45 | 0.061 | 2.203 | 0.765 | 0.144 | 82.72 |
| SM4RT | 0.411 | 95.64 | 0.007 | 0.104 | 0.081 | 0.182 | 67.31 | 6.276 | 43.95 | 0.025 | 0.427 | 0.158 | 0.116 | 92.57 |
| SCOPE-4D (Ours) | 0.442 | 96.11 | 0.001 | 0.054 | 0.051 | 0.033 | 99.75 | 5.022 | 53.08 | 0.010 | 0.211 | 0.114 | 0.050 | 98.80 |
3D tracking (mm) and geometry. D4RT* is an open-source reproduction.
Ablation: training data
| Training data | In-domain average | Hamlyn (OOD) | SCOPE-colon-phantom (OOD) | |||||
|---|---|---|---|---|---|---|---|---|
| Pose | Depth | Depth | Pose | |||||
| AUC@5°↑ | AUC@30°↑ | AbsRel↓ | δ1.25↑ | AbsRel↓ | δ1.25↑ | RTE↓ | ARE*↓ | |
| No finetune (VGGT-Ω weights) | 9.55 | 53.03 | 0.077 | 94.03 | 0.135 | 80.82 | 10.79 | 8.22 |
| SC+SIM+C3VD+EM-S+SA | 35.99 | 74.08 | 0.031 | 99.50 | 0.143 | 80.93 | 11.28 | 7.12 |
| + StereoMIS | 33.10 | 70.02 | 0.032 | 99.53 | 0.142 | 81.40 | 10.51 | 6.83 |
| + EndoMapper-Real | 36.62 | 74.07 | 0.032 | 99.57 | 0.128 | 83.04 | 10.37 | 7.37 |
| Full dataset | 36.02 | 73.68 | 0.030 | 99.59 | 0.129 | 83.77 | 10.71 | 7.37 |
Data composition, geometric fine-tuning only. Hamlyn depth excludes instruments. SC: SCARED, SIM: SimCol3D, EM-S: EndoMapper-Sim, SA: Sano.
Ablation: motion representation
| Variant | Tracking | Pose | Depth | |||
|---|---|---|---|---|---|---|
| EPE↓ | APD↑ | AUC@5°↑ | AUC@30°↑ | AbsRel↓ | δ1.25↑ | |
| SoM (baseline) | 5.94 | 46.58 | 5.67 | 26.86 | 0.050 | 98.82 |
| w/ zero-motion anchor | 5.30 | 50.11 | 6.09 | 27.17 | 0.048 | 98.82 |
| Full CRM | 5.27 | 52.63 | 6.96 | 27.66 | 0.049 | 98.85 |
Long-sequence reconstruction
| Method | ATE↓ | RTE↓ | RRE↓ |
|---|---|---|---|
| VGGT | 93.21 | 23.65 | 15.11 |
| VGGT-Ω | 85.92 | 21.67 | 31.21 |
| SM4RT | 88.95 | 21.29 | 16.98 |
| Endo3R | 77.87 | 14.75 | 22.92 |
| SCOPE-4DSFT (Ours) | 73.52 | 10.38 | 13.38 |
| SCOPE-4D (Ours) | 71.17 | 10.94 | 13.61 |
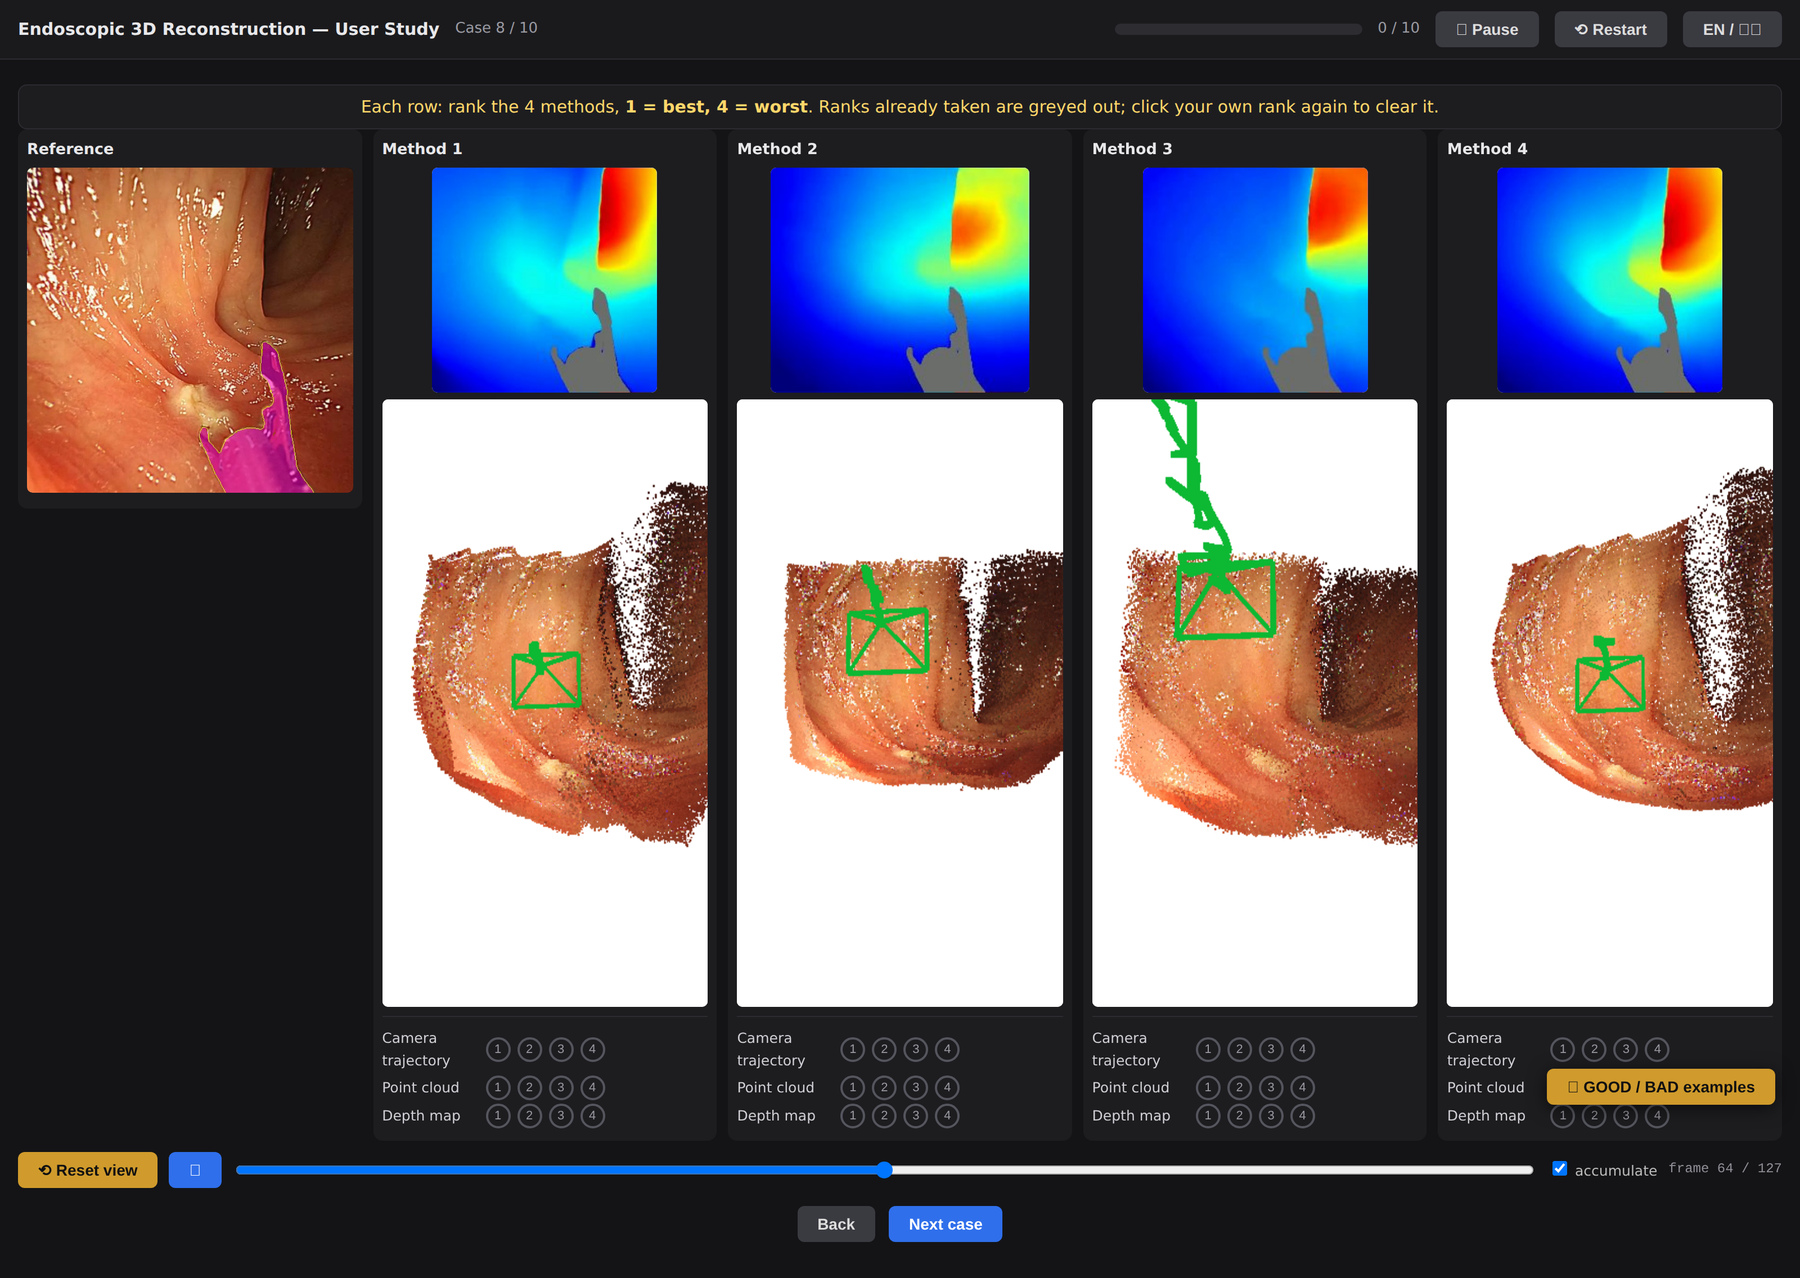
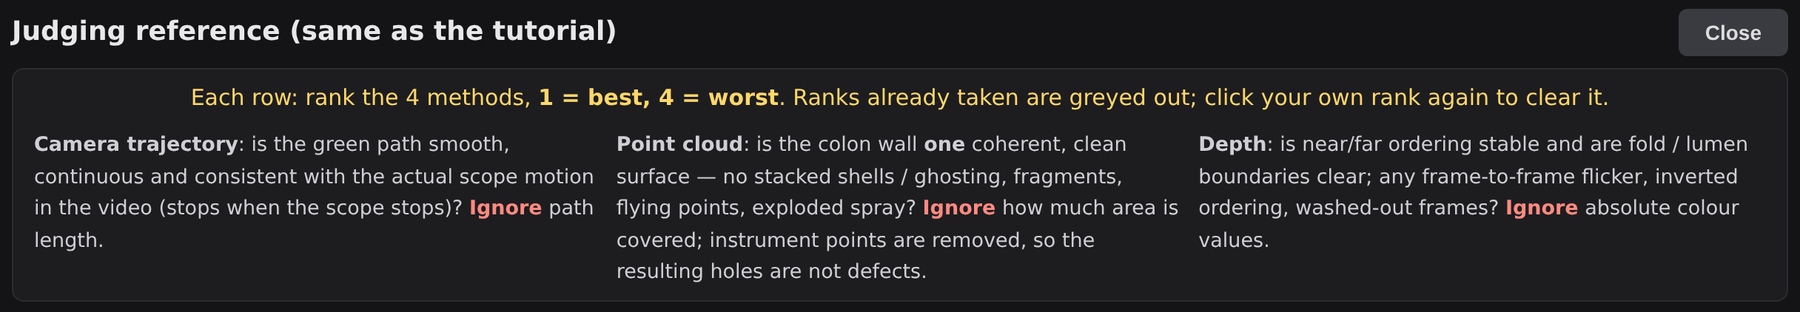
User study
| Method | Camera trajectory↓ | Point cloud↓ | Depth map↓ |
|---|---|---|---|
| VGGT-Ω | 1.93 [1.65, 2.25] | 1.95 [1.65, 2.28] | 1.98 [1.67, 2.32] |
| SM4RT | 2.90 [2.60, 3.08] | 3.22 [2.80, 3.57] | 3.33 [2.87, 3.73] |
| Endo3R | 3.83 [3.53, 4.00] | 3.52 [3.23, 3.78] | 3.37 [3.00, 3.70] |
| SCOPE-4D (Ours) | 1.33 [1.12, 1.62] | 1.32 [1.13, 1.55] | 1.32 [1.13, 1.53] |
SCOPE-colon-real: mean rank from six clinical and biomedical experts on ten clips (1 best, 4 worst), 95% bootstrap intervals.
Study interface
Comparison with fine-tuned SM4RT
SM4RTFT is SM4RT fine-tuned on SCOPE-5K with the same training budget as SCOPE-4D.
Geometry and camera stability
Hamlyn
Hamlyn
SCOPE-colon-phantom
EndoMapper-Real
3D tissue tracking
Breathing motion and tool interaction StereoMIS
Tool interaction Sano